
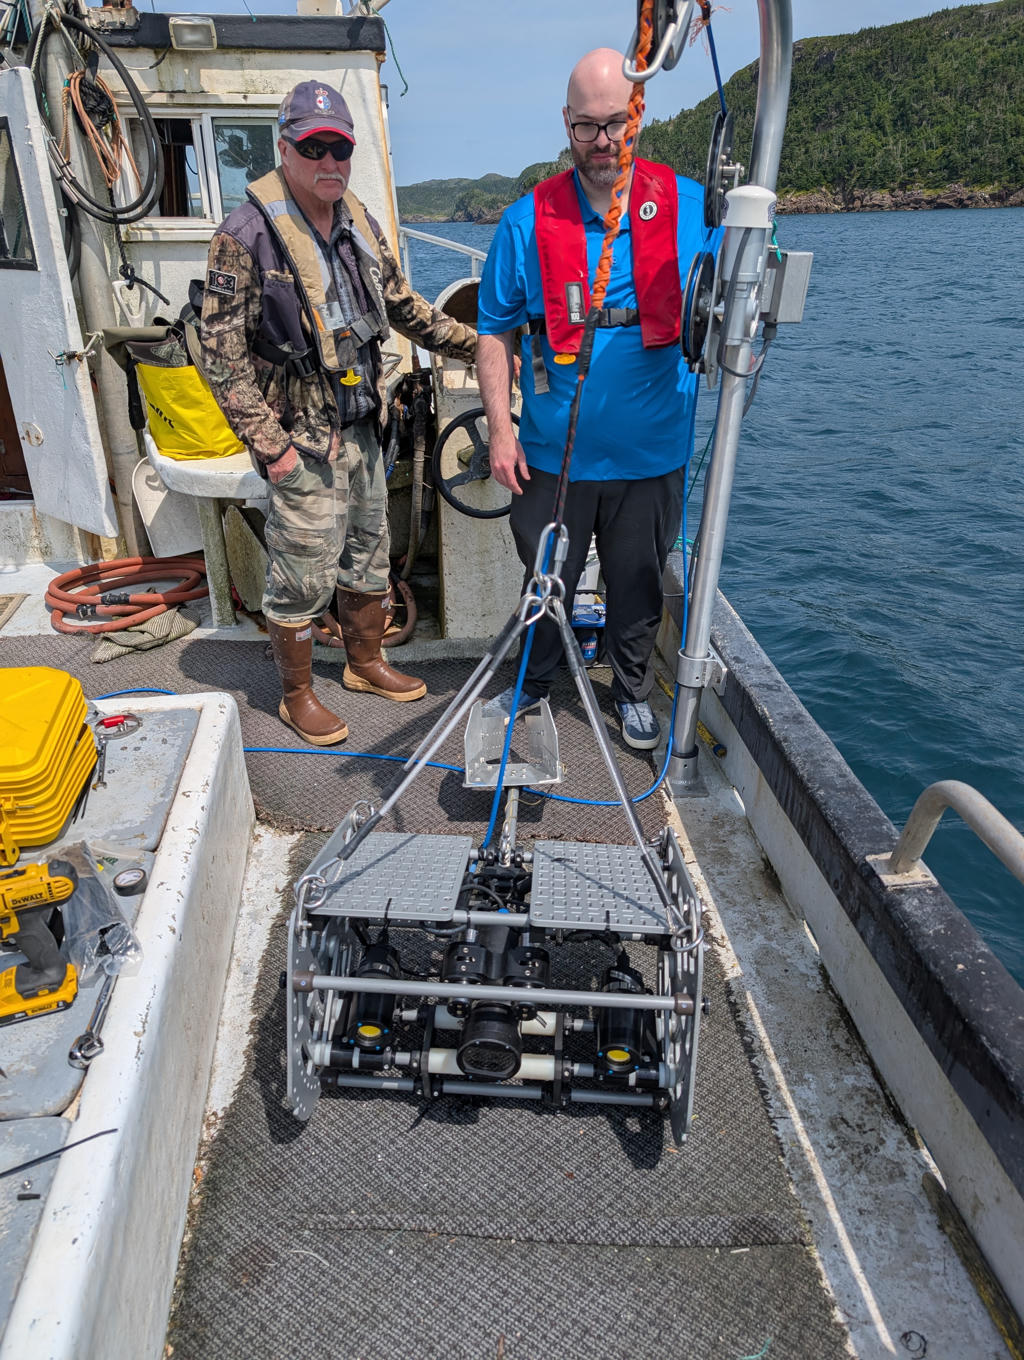
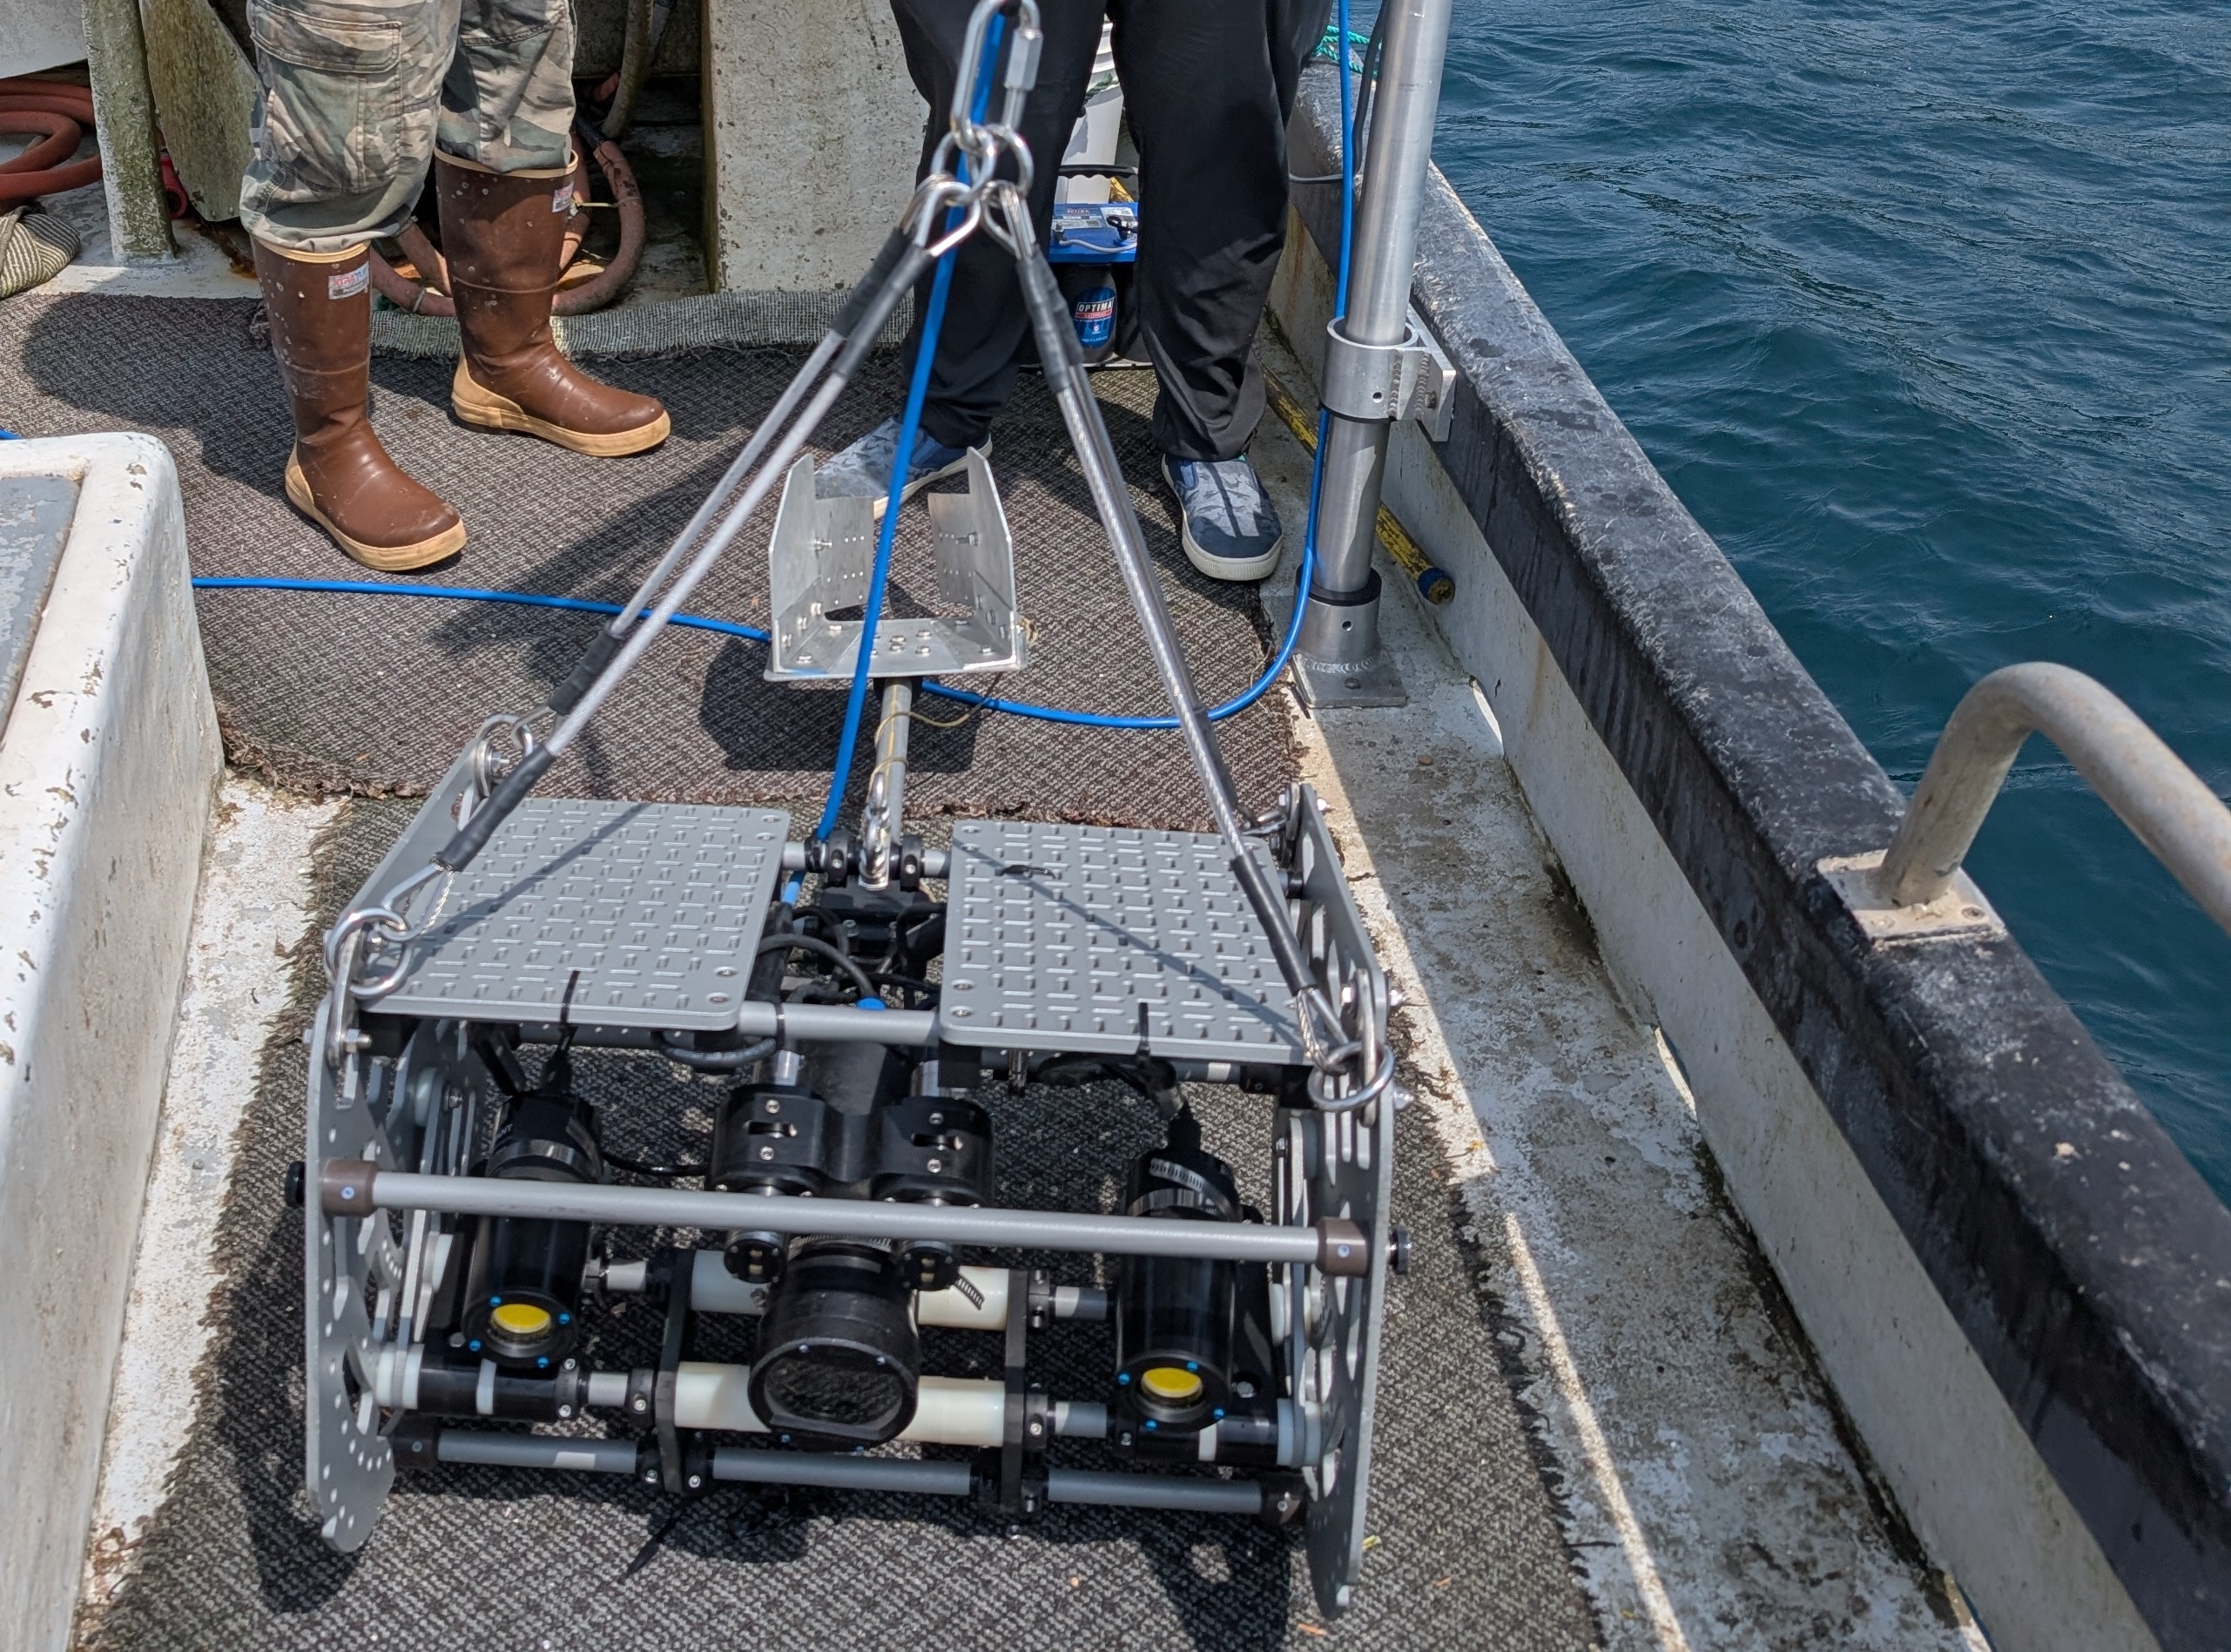
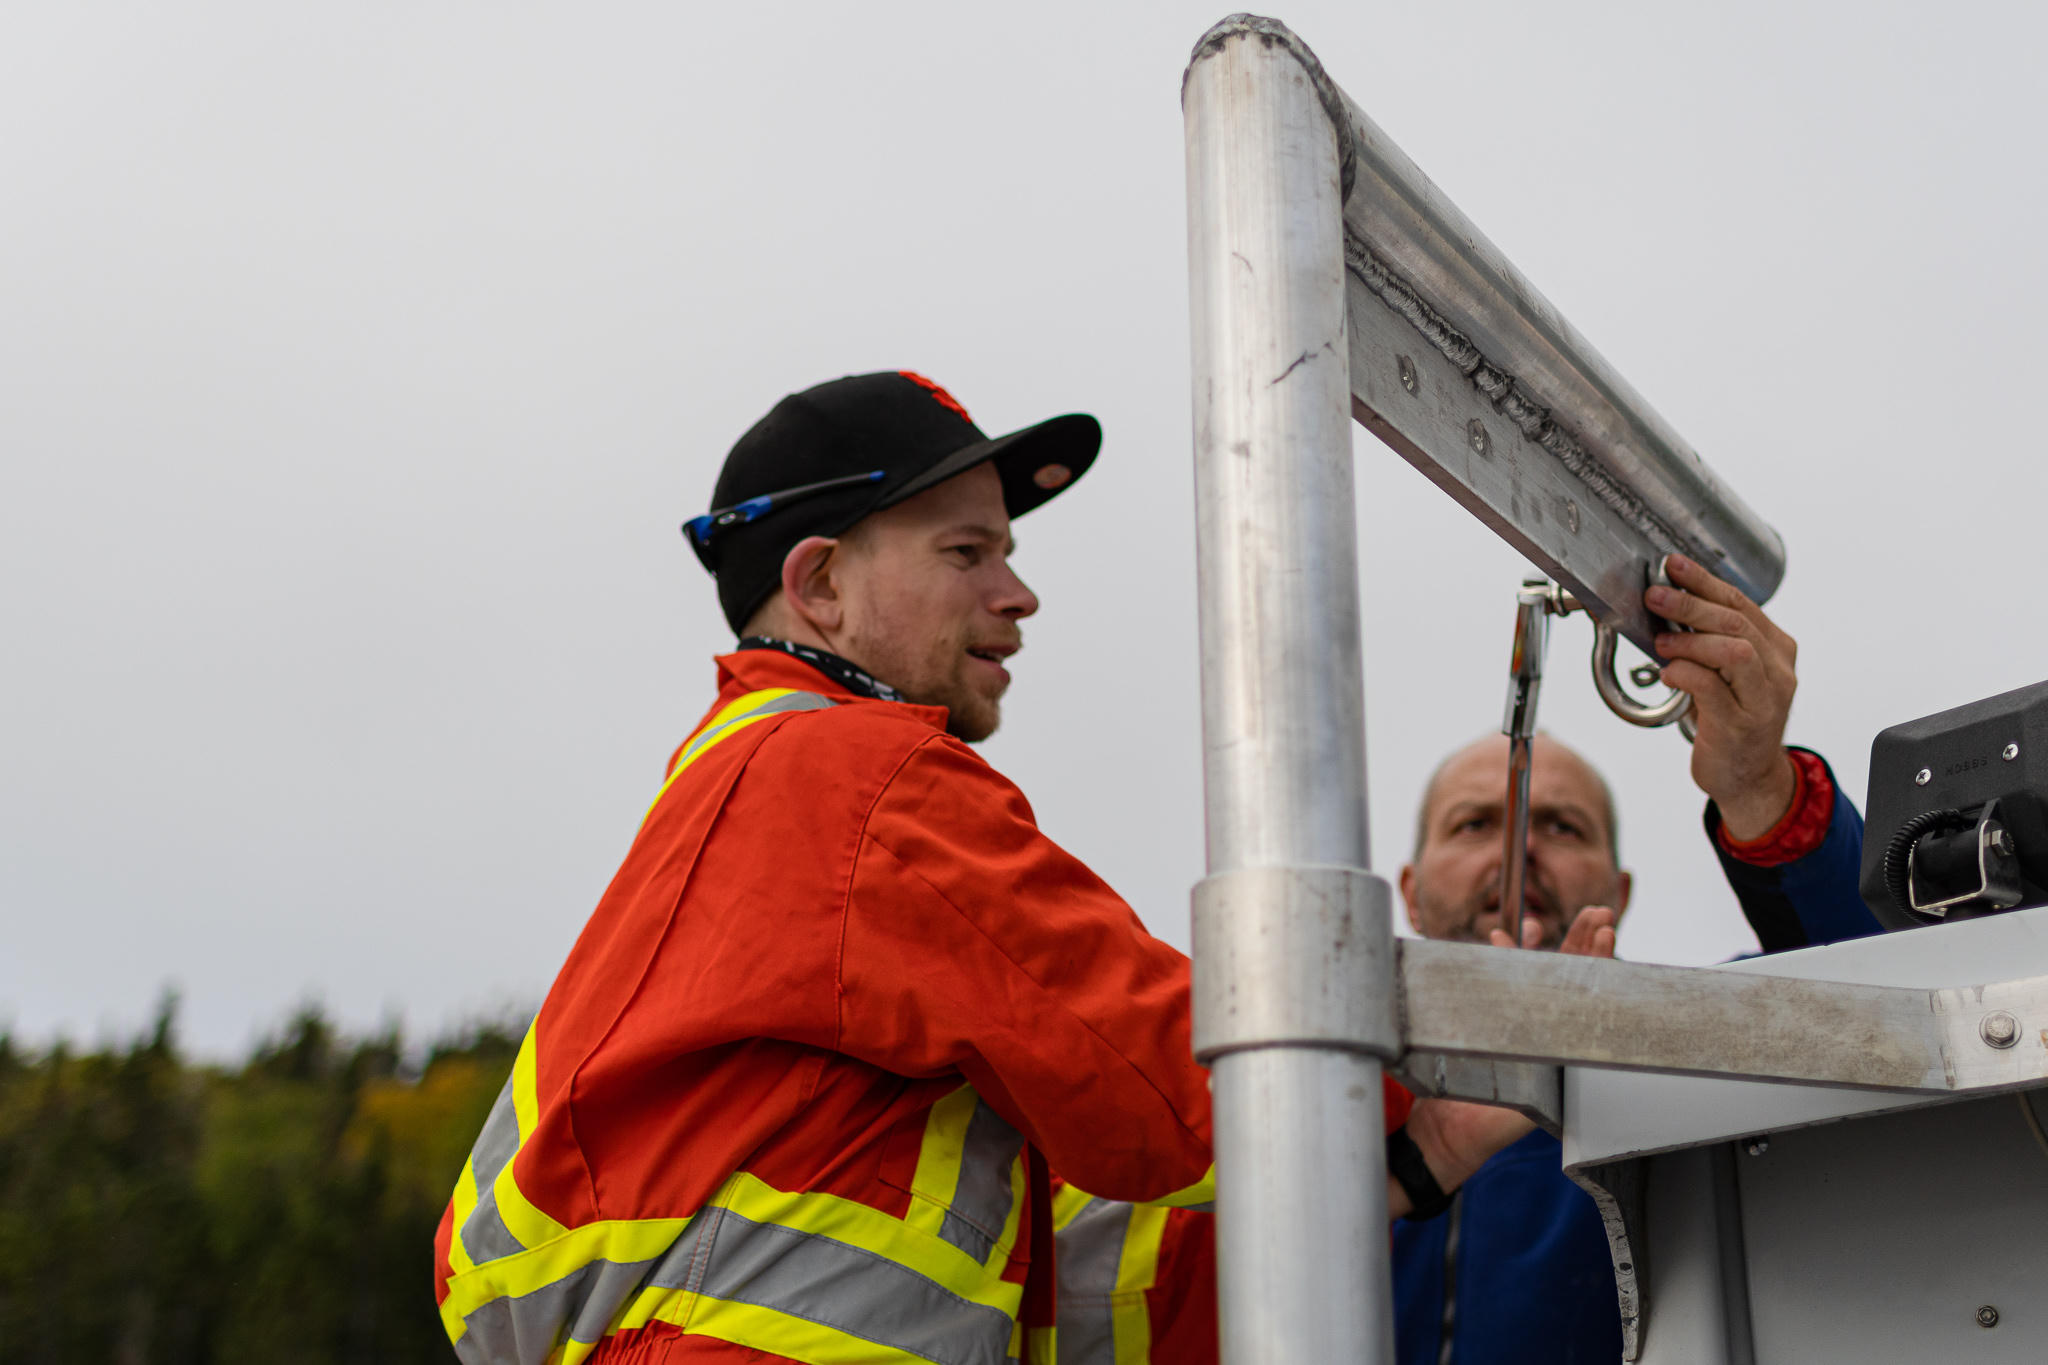
Mechanical Integration
Using a comprehensive mechanical integration document, SubC will work with you to determine how best to deploy the system on your particular vessel, whether that's a side-mounted boom arm, a rear-deck A-Frame, etc.
We will help identify:
-
Where to locate the winch
-
The order of operations for deployment, dropping, and retrieval
-
How to work around existing equipment or modify current equipment to fit the tow system
-
Where to locate the winch control system and the Rayfin Control
-
What cabling needs to be run
-
What modifications might need to be made to the vessel
-
Power and network requirements
-
Where/how to mount equipment
-
Any additional information required